Features:
- Controls two servo or stepper axes with an output mode selected independently for each axis.
- Exchanges motion commands over Ethernet, RS-232, or the configurable RS-232/RS-485 interface.
- Retains the controller and panel-mounting hardware while the -NK configuration omits the standard ship kit.
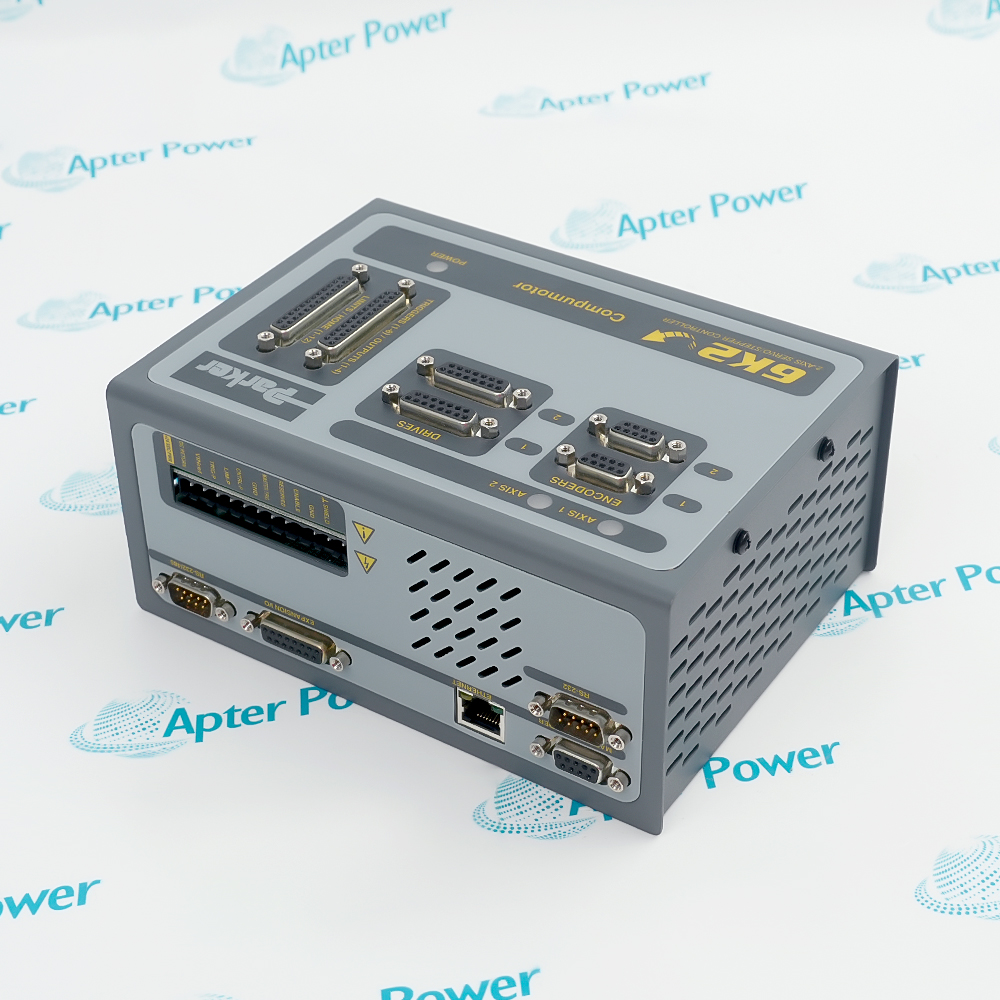
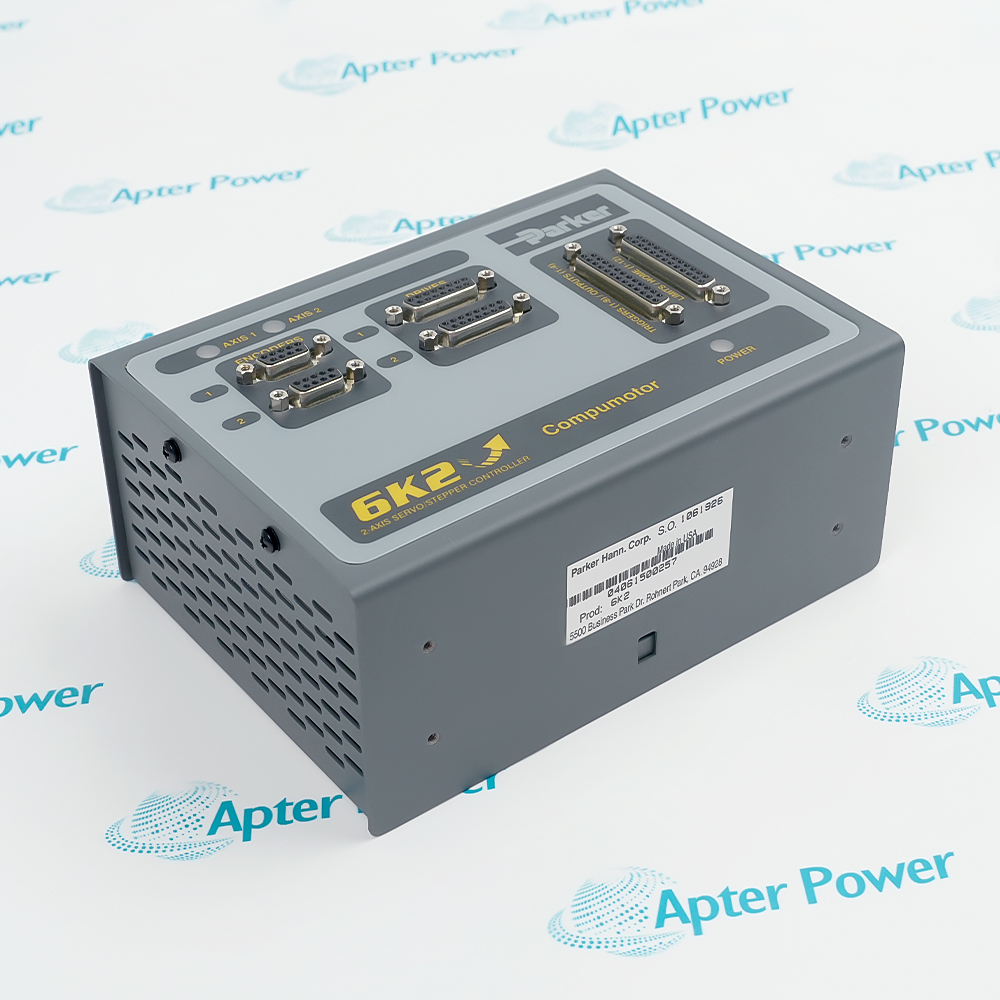
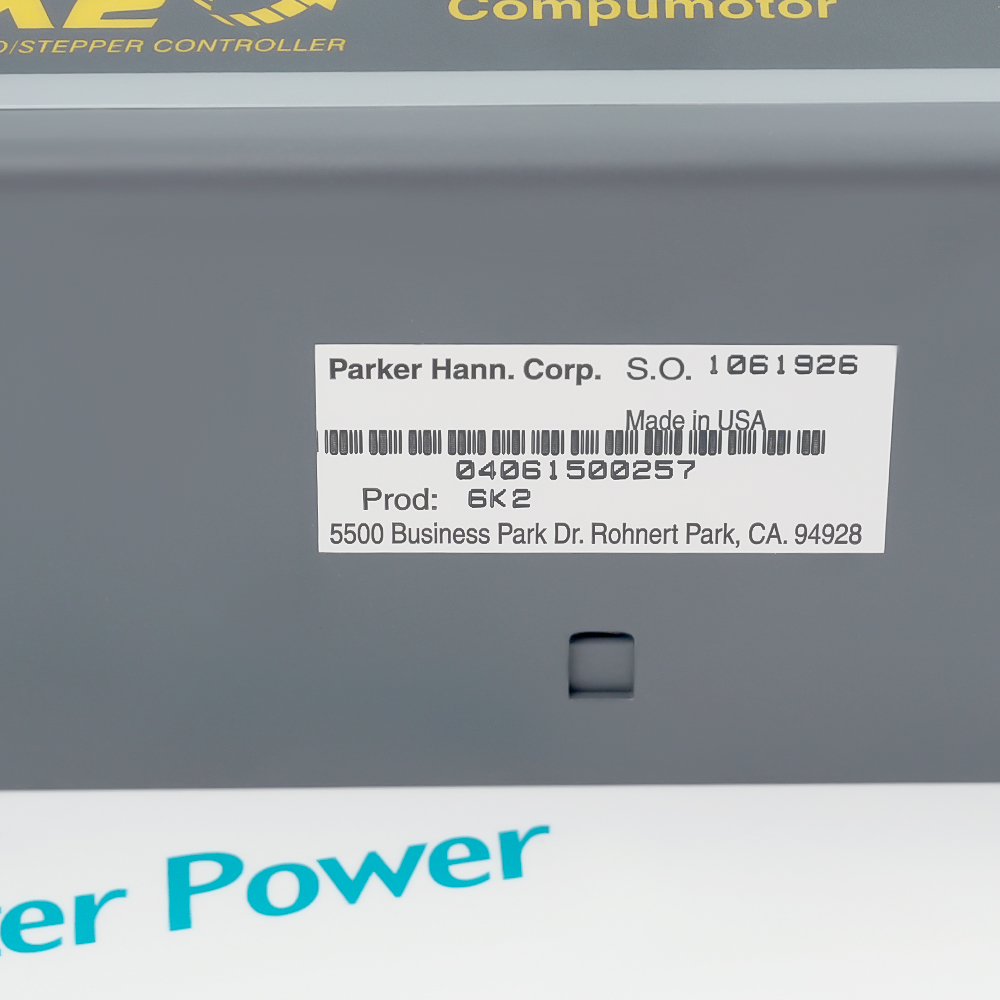
Parker 6K2-NK 1061926 combines motion calculation, feedback processing, machine I/O, and host communication inside one standalone controller.
Encoder signals return actual position to the two axis loops, while trigger, limit, home, and digital-output circuits connect the motion sequence to machine events.
The EVM32 connector extends the controller toward additional digital, analog, or relay I/O without changing the two-axis identity.
Parker 6K2-NK 1061926 Two-Axis Servo/Stepper Motion Controller without Ship Kit Manuals,Datasheets,Link
Important Notice: Other accessories, manuals, cables, calibration data, software, etc. are not included with this equipment unless listed in the above stock item description. All prices are shown in USD.
Command and Feedback Paths
- Output choice: Each axis can send either a ±10 V servo command or step-and-direction signals.
- Encoder return: Incremental feedback enters through a differential or single-ended 5 V TTL-compatible encoder interface.
- Control interval: Servo calculations can update each configured axis at 62.5 microseconds.
- Range handling: The command engine maintains signed position and velocity values across the documented controller ranges.
Host and Multidrop Connections
- Ethernet channel: The RJ45 interface carries 10Base-T traffic through TCP/IP or UDP.
- Programming port: A dedicated RS-232 connection supports controller programming and host communication.
- Configurable port: The second serial path can operate as RS-232 or two- or four-wire RS-485.
- Serial chain: Configured serial units can be arranged in a daisy-chain or multidrop network.
Onboard Event Connections
- Trigger capture: Nine fast inputs accept machine-event signals on the two-axis controller.
- Travel references: Limit and home connections supply axis reference and end-of-travel states.
- Digital action: Four sinking outputs switch user-supplied 5–24 V DC loads.
- Signal commons: The connector layout separates encoder, drive, trigger, limit, and power references.
Included and Omitted Items
- Controller identity: The 6K2 hardware remains a complete two-axis controller.
- Omitted package: The -NK option excludes the standard 6K-KIT documentation and crossover-cable package.
- Mounting hardware: Panel-mounting brackets and screws remain included independently of the ship kit.
- Expansion boundary: EVM32 modules and their SIM cards remain separately selected accessories.